Found late
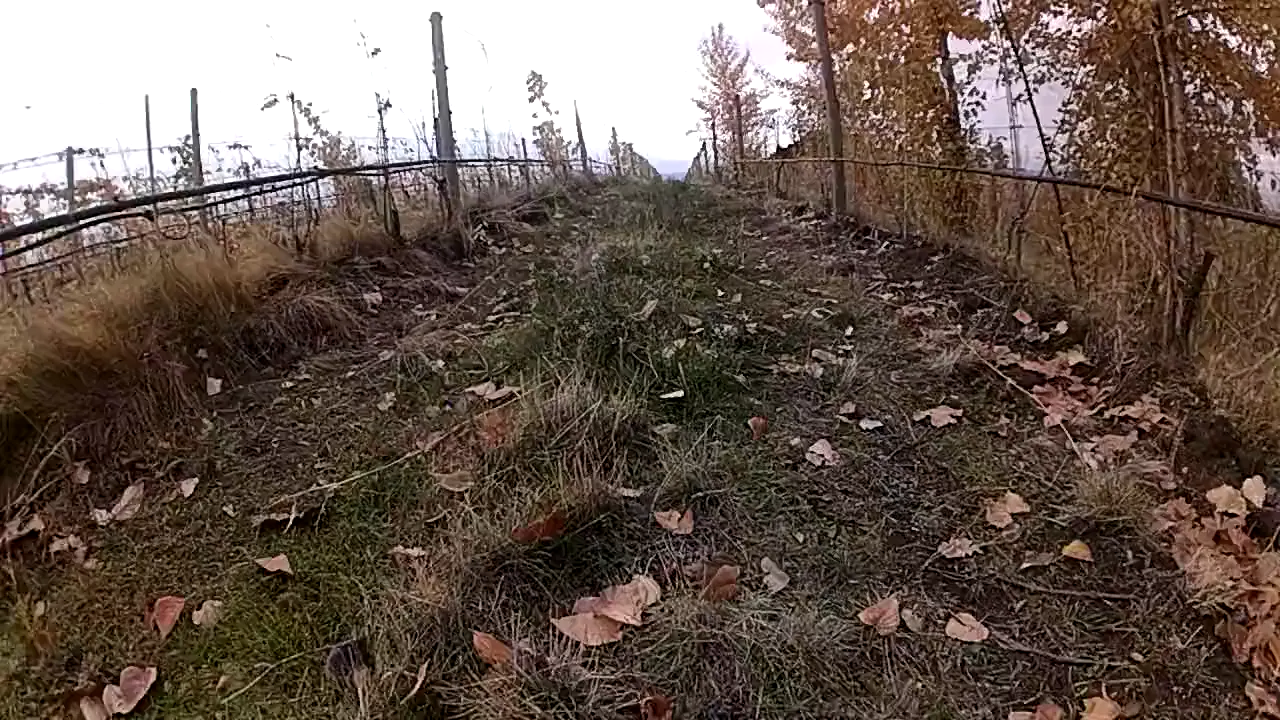
Gopher mounds and ground damage can be easy to miss until the trees or vines above them are already affected.
Field robotics · Kelowna, BC
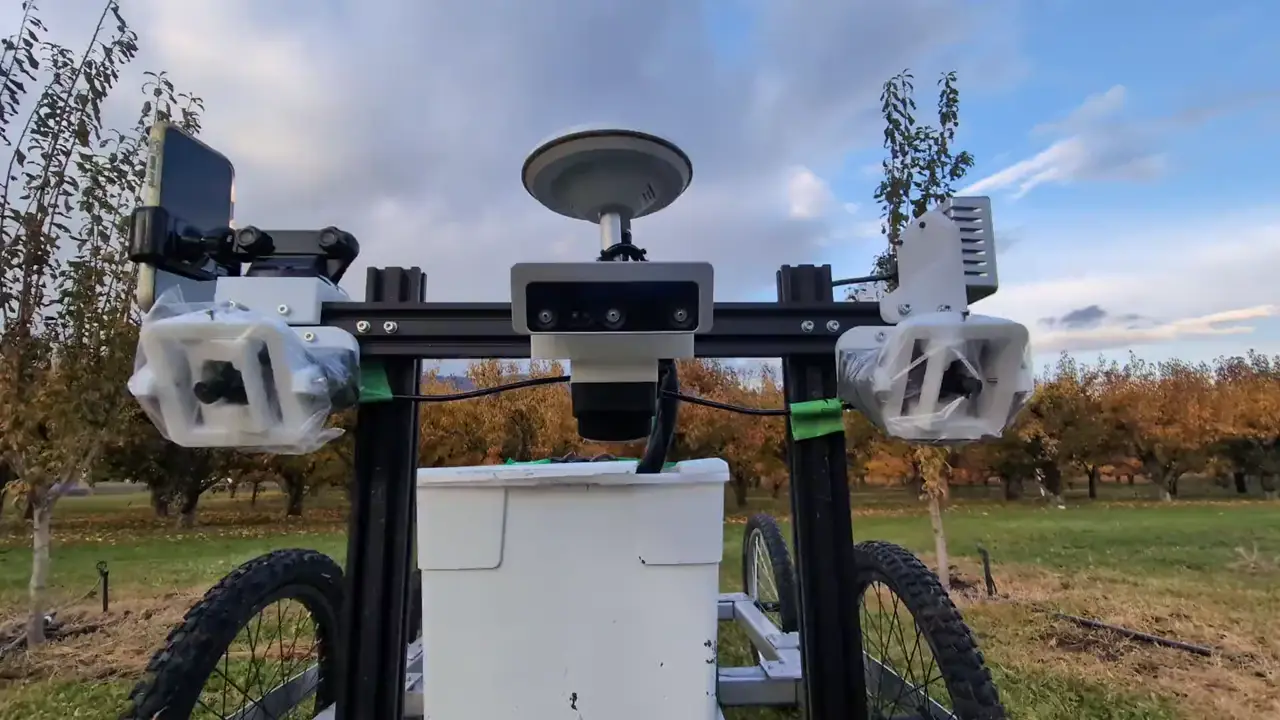
Robots that monitor and tend to every tree & vine. Today, that is a human-pushed sensor cart that records the rows it passes and ties each gopher mark to a place in the block, with irrigation issues and canopy health on the roadmap.
What we do
We collect it with a human-pushed sensor cart. Its cameras record each row it passes; early prototype models flag possible gopher mounds and sprinkler stakes, and a person confirms what goes in a report. A leaf scanner is in bench testing.
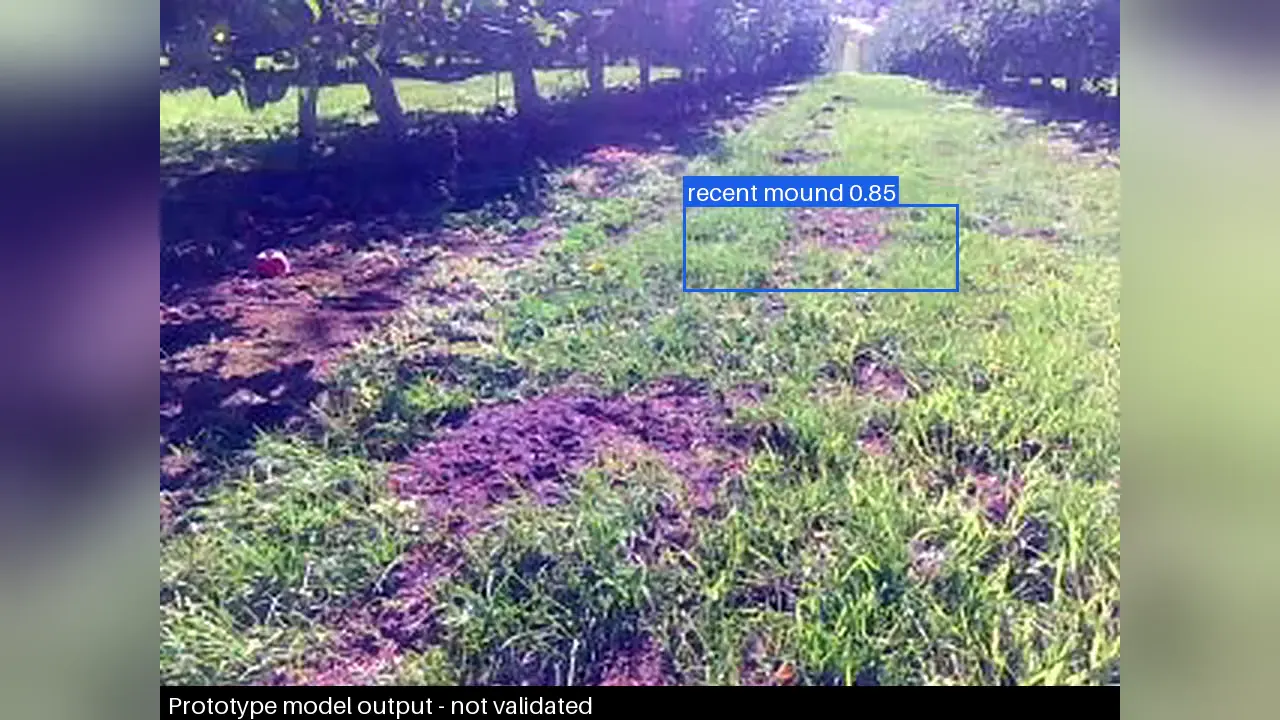
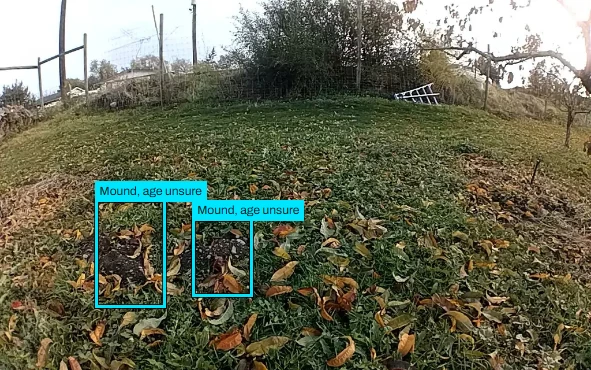
Ground cameras record each row. An early model flags frames that may show mounds; a person confirms or rejects each one before it counts.
Okanagan orchard, October 2026. Model output; prototype, not validated. Demo-only model, trained on footage that includes this pass.
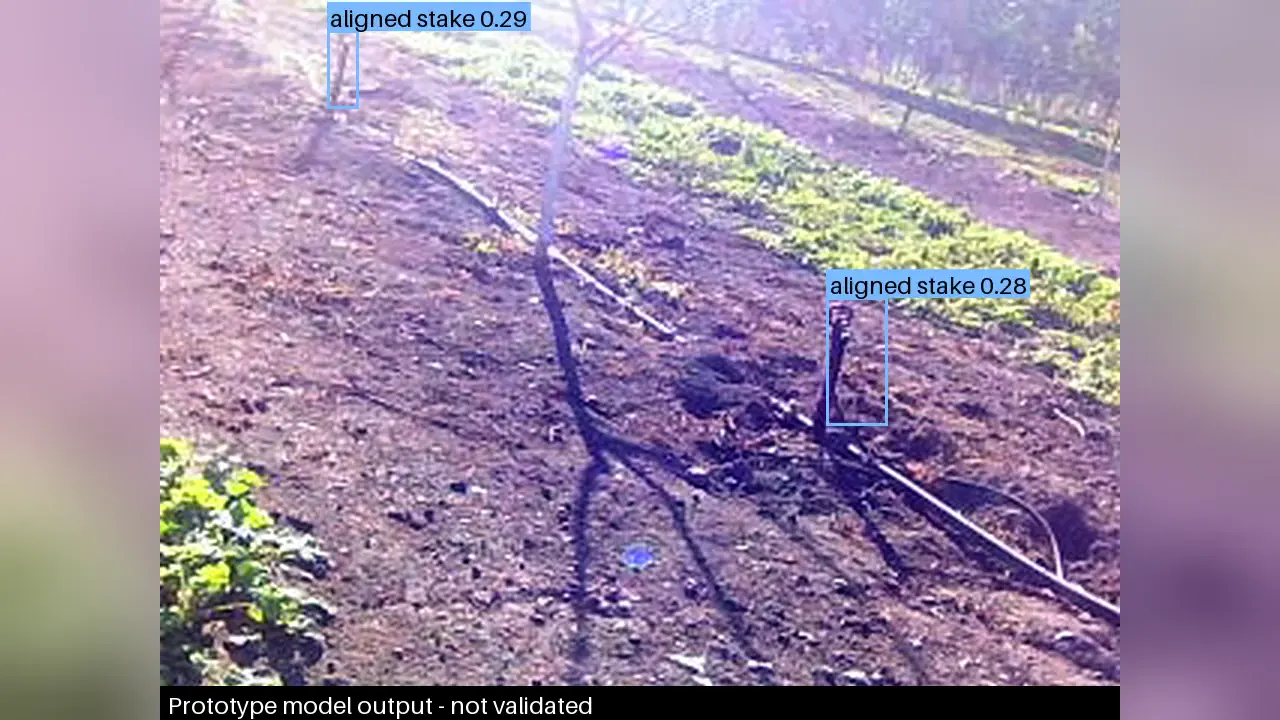
An early stake model marks sprinkler stakes in cart camera footage. Growers have shown interest in stake checks.
Okanagan orchard, October 2026. Model output; prototype, not validated; not yet checked by a person. Demo-only model, trained on footage that includes this pass.
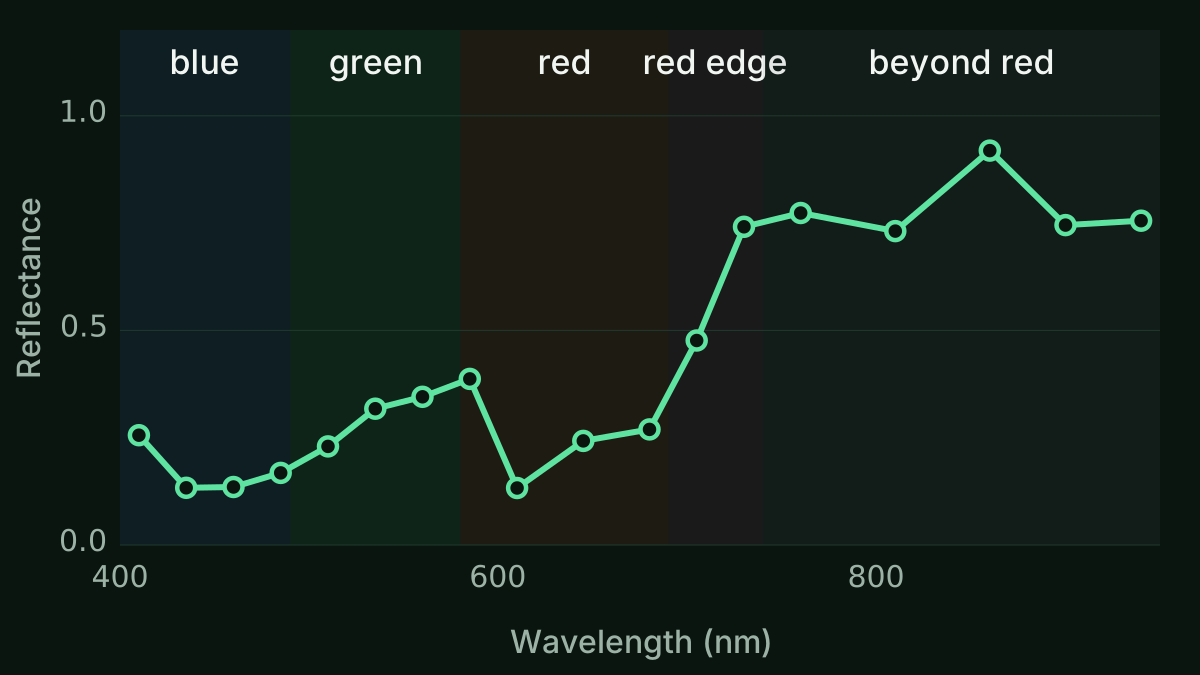
Reads relative leaf reflectance across 18 bands, 410–940 nm. It is not yet calibrated against lab tests, so it gives no nutrient advice; pairing it with lab tests is planned for 2027.
One apple leaf, bench reading, October 2026. Raw relative reflectance.
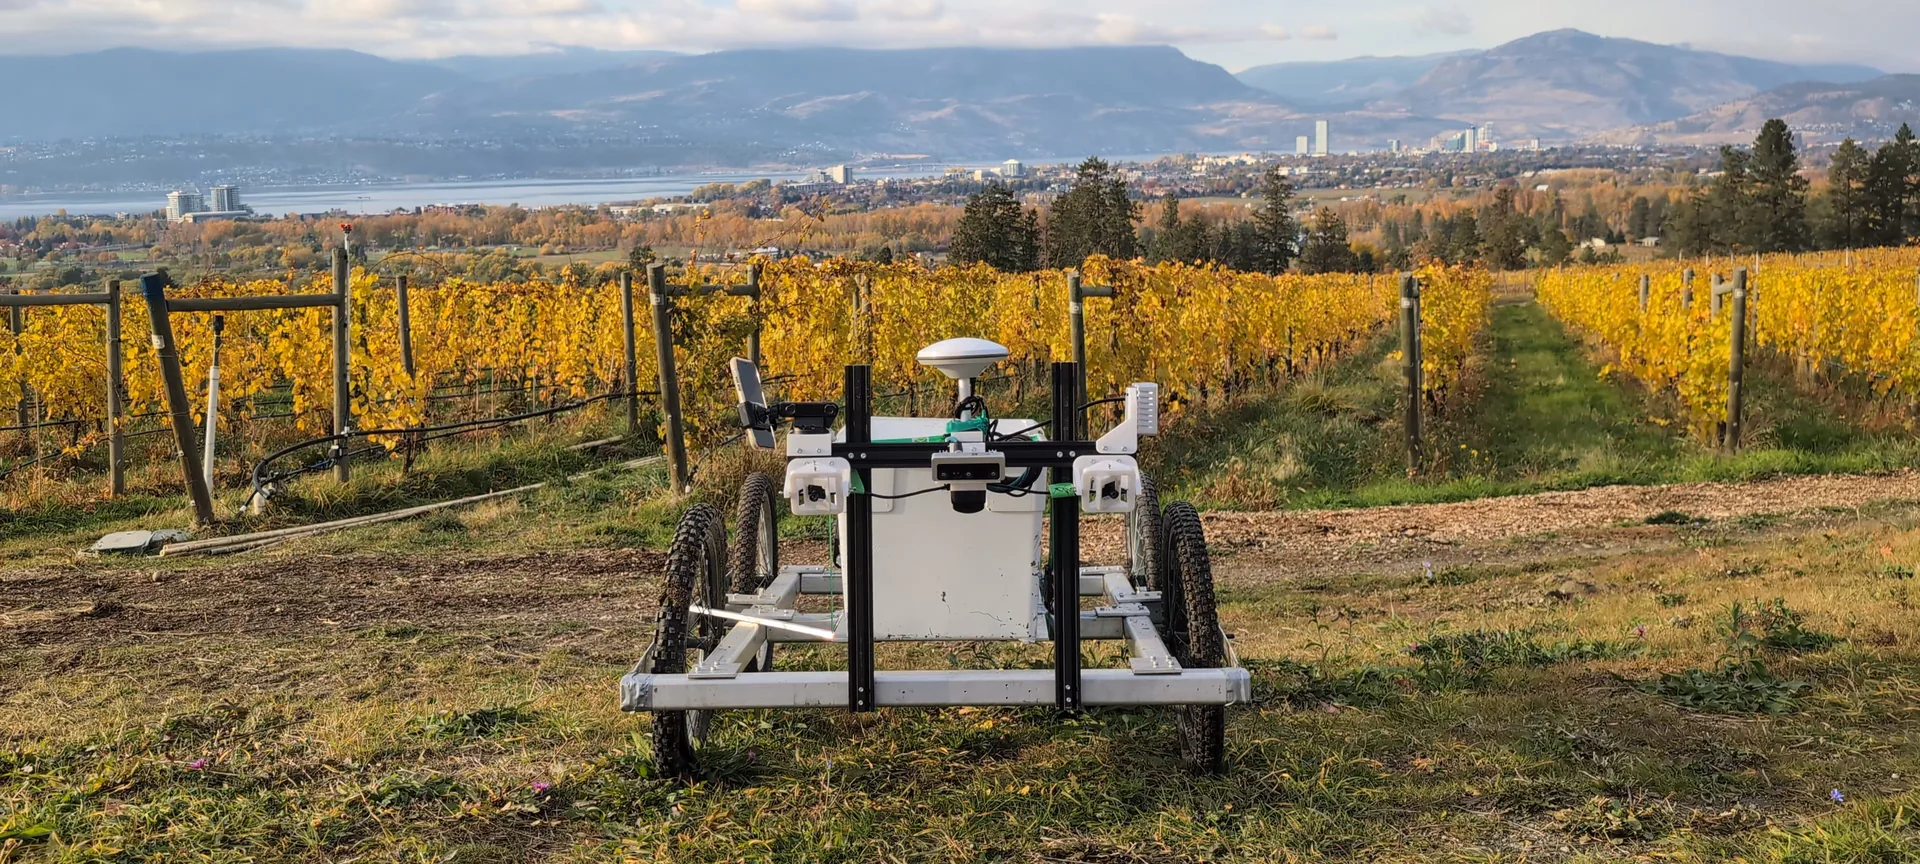
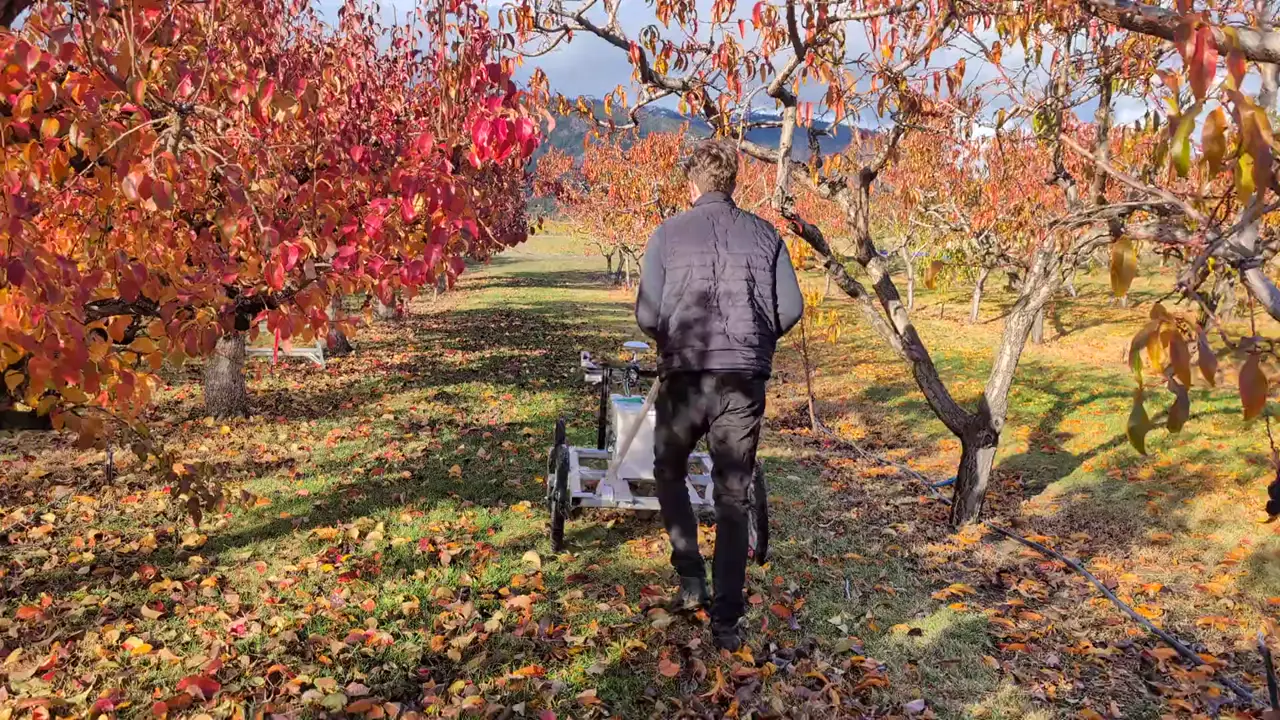
Push the cart down each row. Cameras, lidar and GPS record as it goes.
Early models flag frames worth a look. A person confirms or rejects each one before it counts.
You get a map of reviewed marks by row and location, as leads to check on the ground.
01The problem
Most of the growers we interviewed told us they want gopher control. Today, scouting a block means walking it.
Gopher mounds and ground damage can be easy to miss until the trees or vines above them are already affected.
A problem spotted mid-row may not be tied to a precise location, so follow-up can mean walking the row again.
Without a consistent record, it can be hard to tell whether a block is getting better or worse over a season.
02The platform
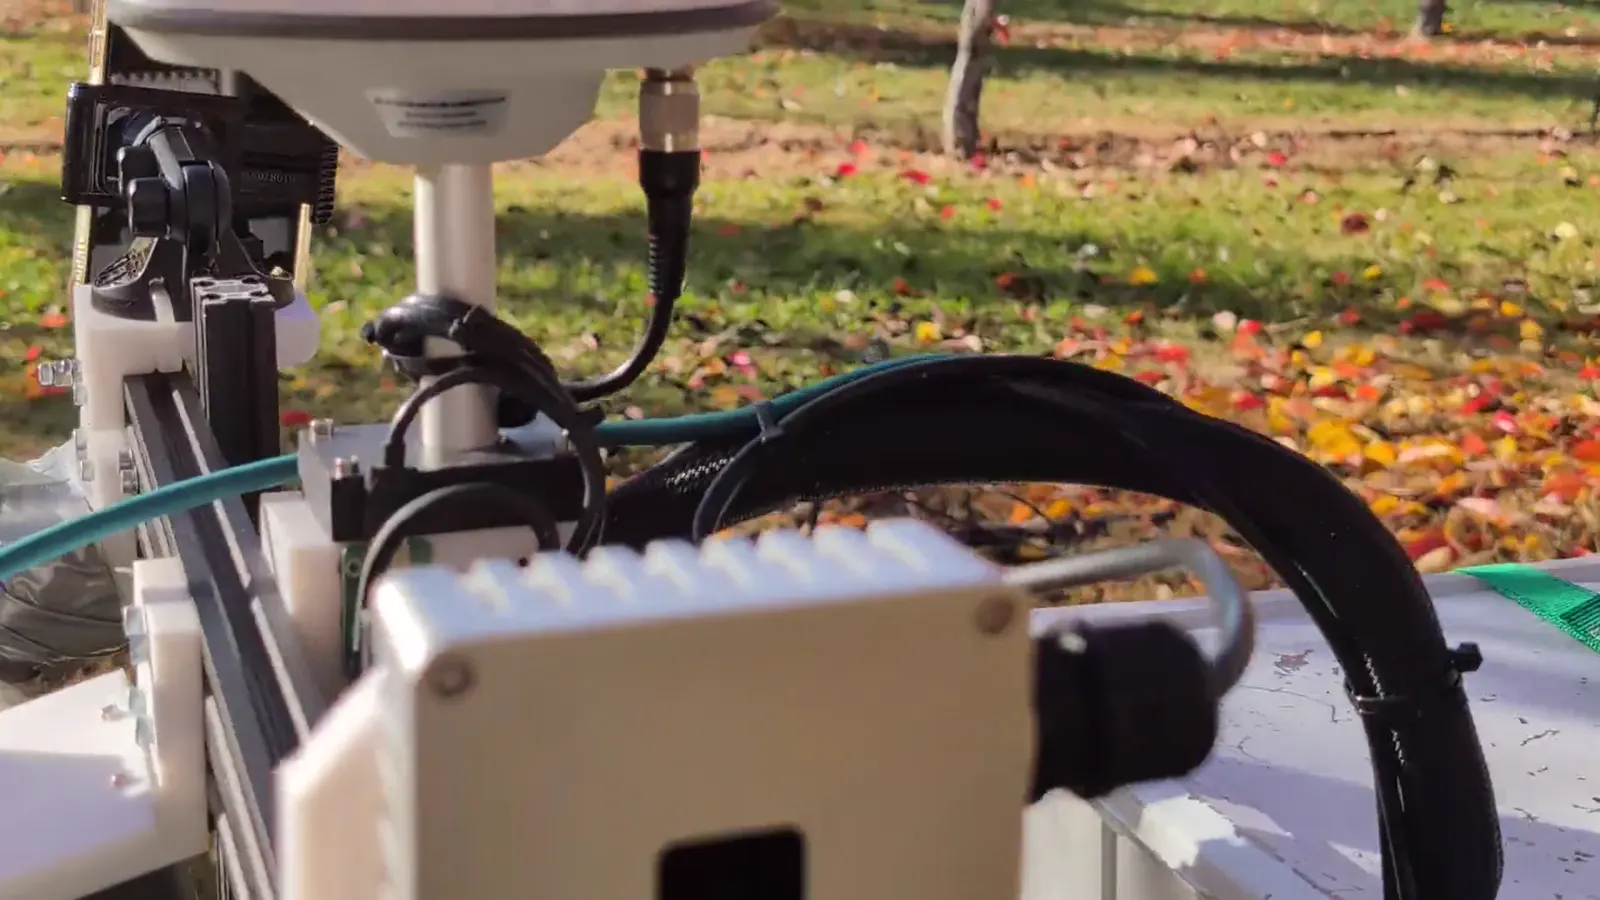
An operator pushes the cart down the row at walking pace. It records the ground along the row, and every finding comes back tied to a place in the block.
Mounds are marked by the operator during the pass; a person reviews candidate findings before they go in a report.
Each finding is tied to a row and an approximate position, so a follow-up check can start at the spot.
Findings are tied to row and position, so the same row can be compared between visits.
Workflow illustration
We aim to add capabilities to the same platform over time.
03What the cart sees
Our first models rank gopher-mound frames and test box detection. Grower reports stay human-confirmed. Irrigation and canopy work are on the roadmap.
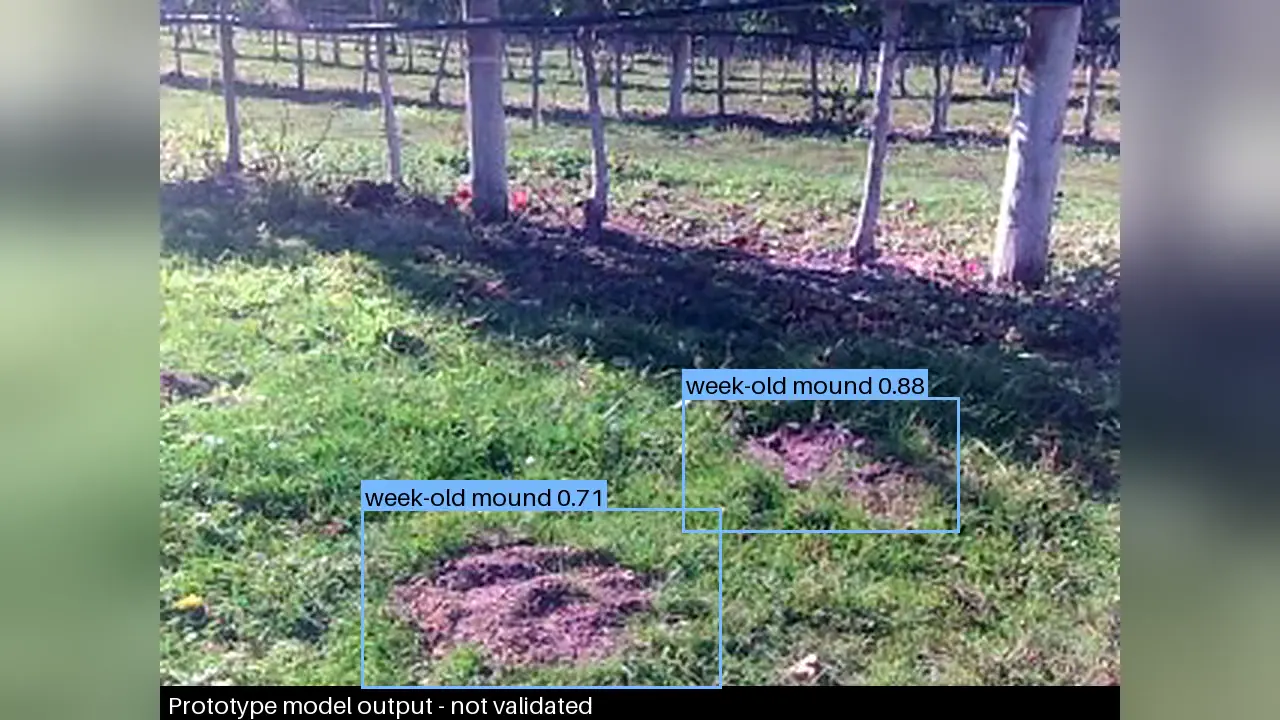
Grower reports stay human-confirmed. Gopher detection is still a prototype; field accuracy has not been validated.
Growers have shown interest in irrigation-stake checks.
Canopy scanning is planned; it is not a validated capability today.
Not yet claimed: detection accuracy, and time or cost saved per block. We'll publish these once they come from validated field data.
04What you get back
Explore three ground scouting reports: row maps, operator marks and camera photos, brought together in one view.
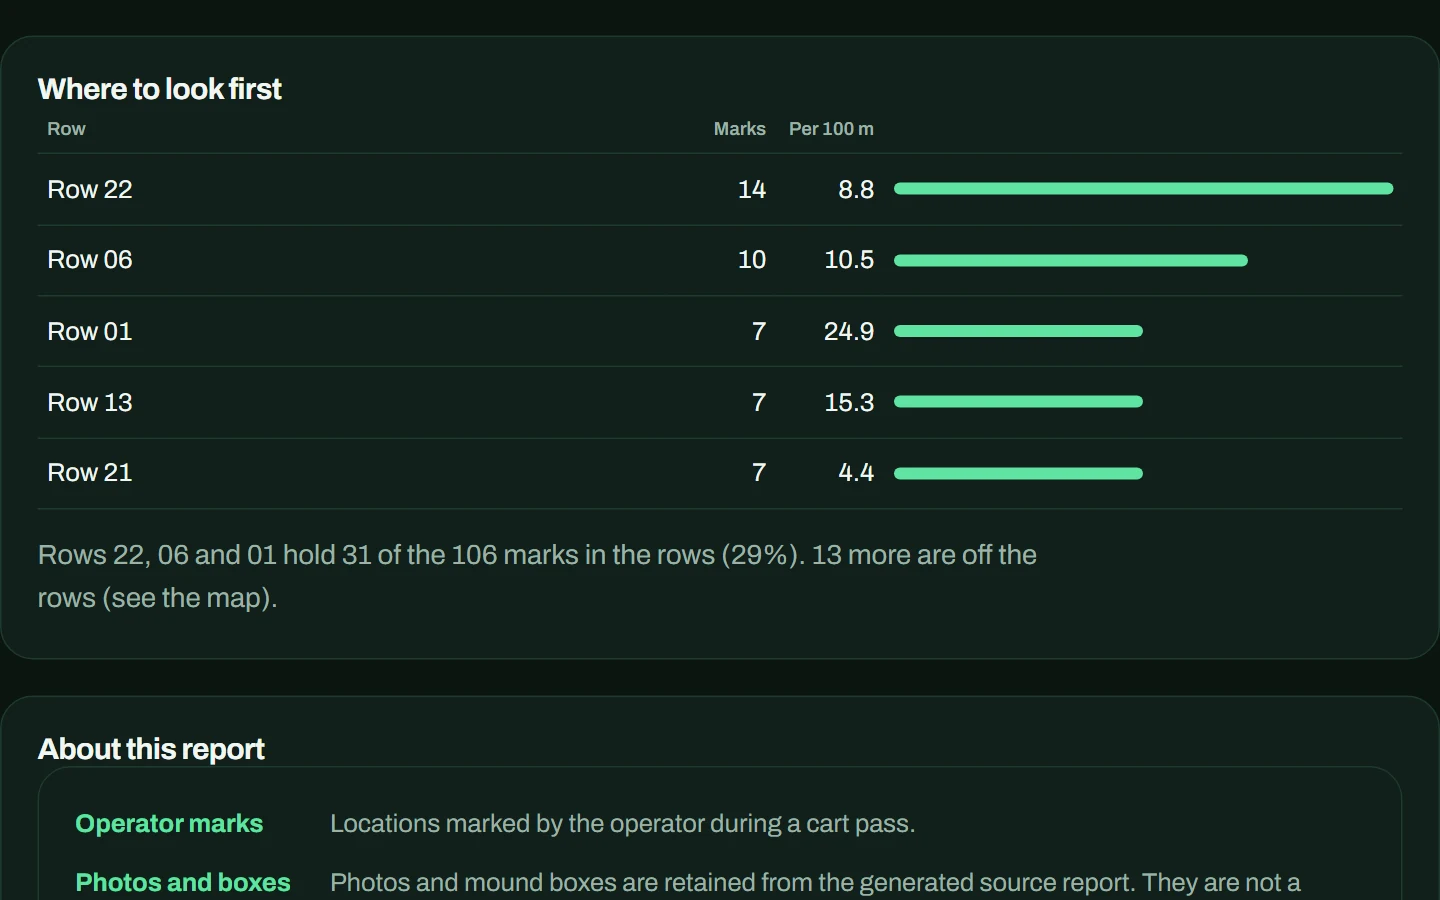
A ground scouting report with an interactive row map and 78 camera photos.
Explore this report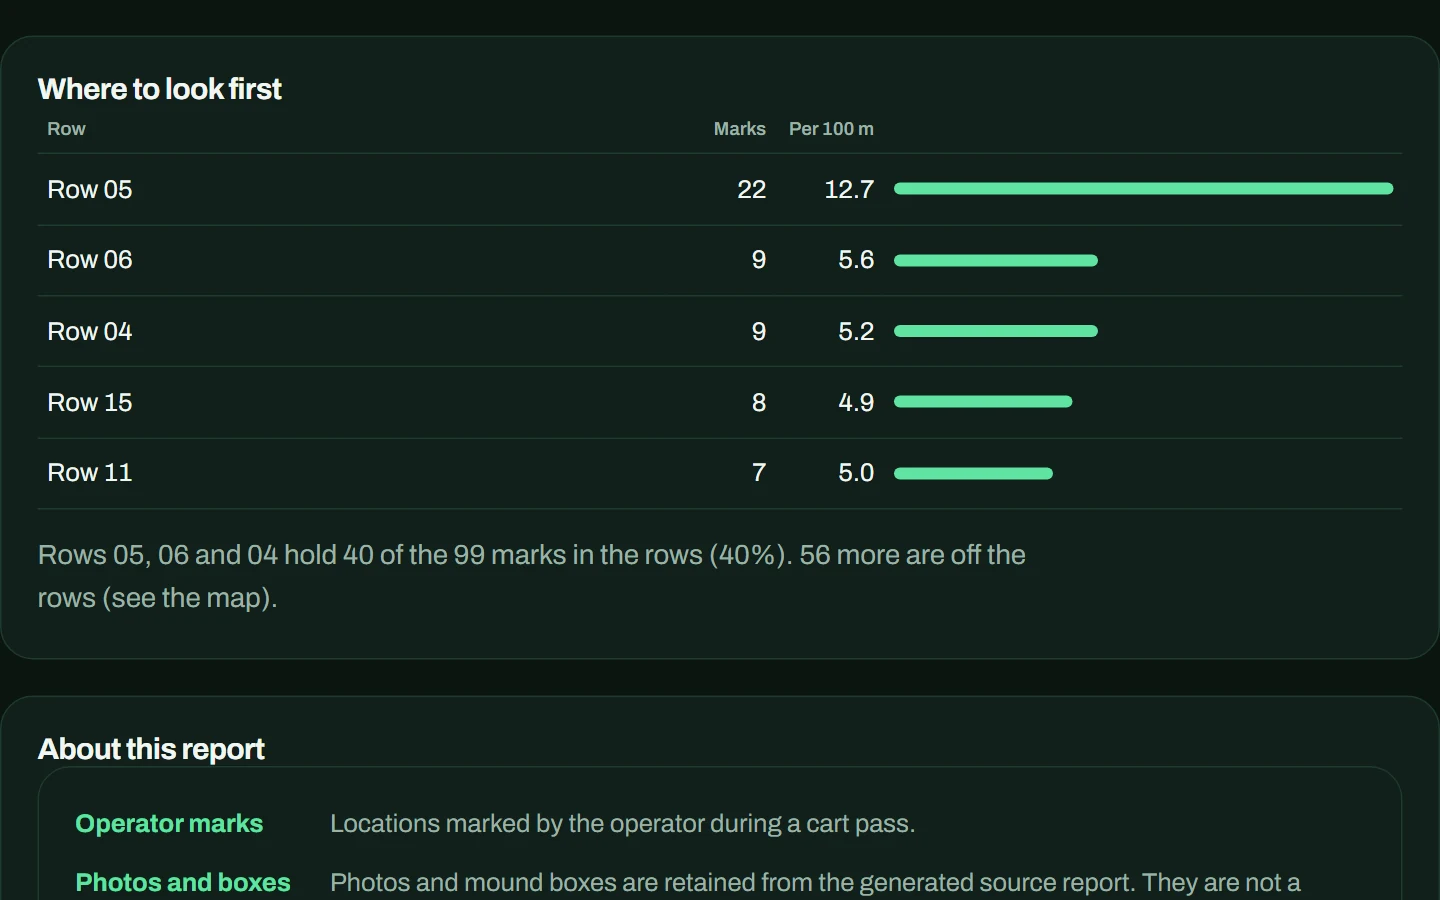
A ground scouting report with an interactive row map and 40 camera photos.
Explore this report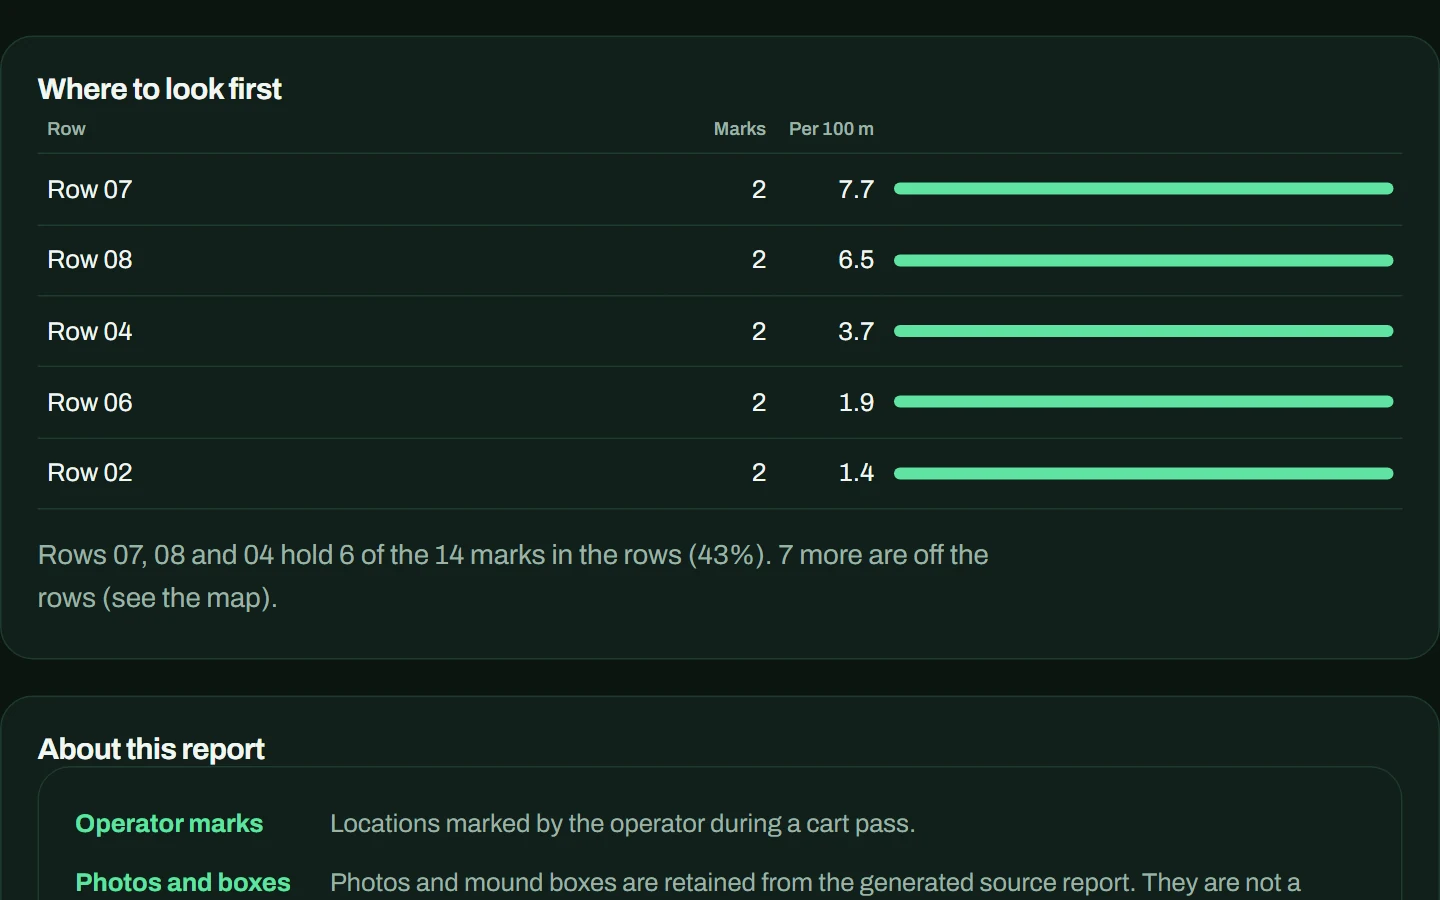
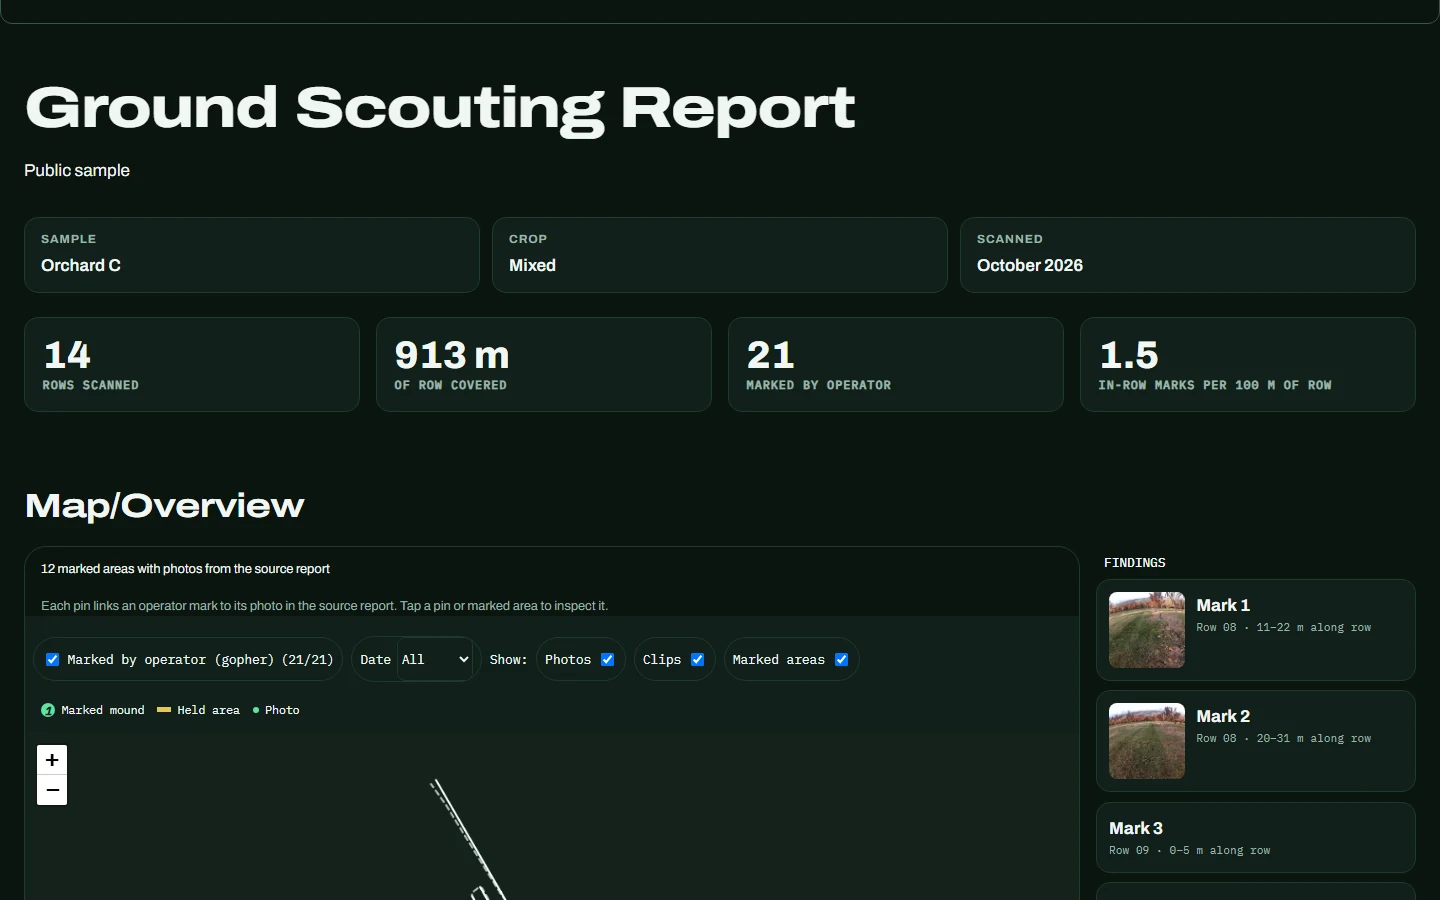
A ground scouting report with an interactive row map and 12 camera photos.
Explore this reportThese are anonymous copies of real field reports. Grower names, exact visit dates and geographic coordinates have been removed. The maps show the scanned rows on a 2018 public aerial photo, rotated and cropped to the scanned blocks. Findings are leads to check on the ground.
05Pilots
We offer free field demos to Okanagan growers this season, and a pilot can follow a demo. Here's what to expect.
We talk through your blocks, what you're watching for, and which rows make sense to start with. We'll also ask what other pain points you have, and any ideas you have for the platform.
We walk the agreed rows with the cart. We'll agree on which rows and how long with you up front, and schedule around your work.
Every candidate finding is checked by a person, and anything we couldn't confirm is marked that way.
You get your block map and findings, and we go through them together. Early on every finding is reviewed by hand, so turnaround is agreed with you up front and may shorten as detection improves.
Field demos are free. If a pilot follows, we agree its terms with you in writing first.
You own the raw data collected on your land. We keep a copy to train our detection models, and delete it after training if you ask.
The cart is pushed by hand down existing rows with at least 1.5 m clear and doesn't need to touch the trees or vines.
06Roadmap
We aim to add capabilities to the same platform over time.
Free field demos with Okanagan growers, with each finding checked by a reviewer.
Planned: ground issues and canopy condition recorded alongside gopher activity, without a second walk.
A bench prototype reads relative leaf reflectance. It is not yet calibrated against lab tests, so it gives no nutrient advice; pairing it with lab tests is planned for 2027. Soil-probe timing depends on scanner progress and funding.
Under-row weeder field testing is planned for 2028. Pruning follows on a robot of its own, with no date set.
07FAQ
The cart is pushed by hand down an existing row with at least 1.5 m clear and only takes pictures and measurements; nothing on it is meant to touch the trees, vines or fruit.
No. The cart runs on its own battery, and the operator's phone provides the data connection.
The cart moves at walking pace down one row at a time, and visits are scheduled around your work.
You own the raw data collected on your land. We keep a copy to train our detection models, and delete it after training if you ask.
We're based in Kelowna and currently working with growers in the Okanagan.
08About
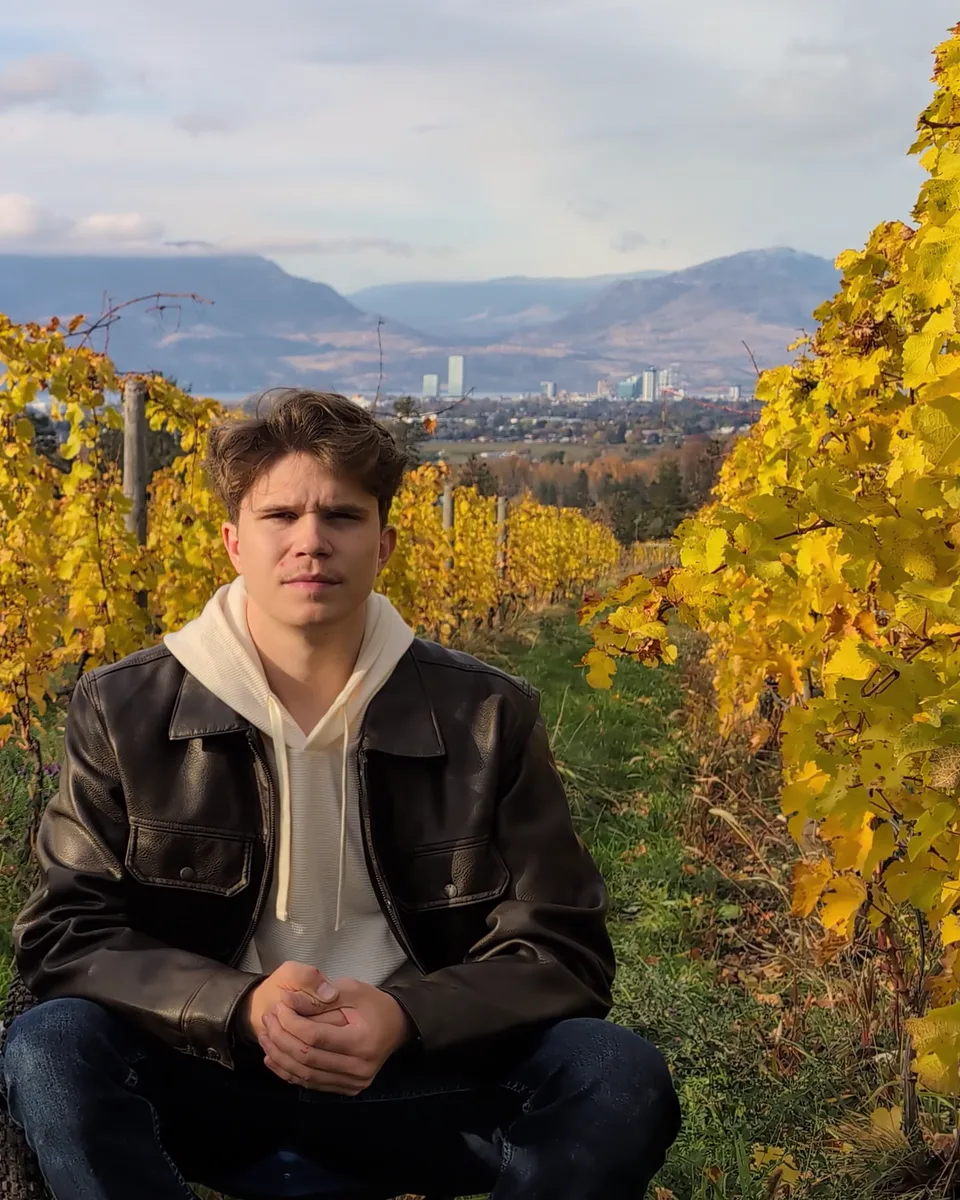
Iron Leaf Robotics Inc. is a British Columbia company founded in Kelowna by Ryan Collins, a solo founder and registered EIT with an electrical engineering degree (mechatronics option), production robotics experience at 4AG Robotics and aerospace electrical leadership at UBC Okanagan. Ryan has been full-time on Iron Leaf since October 20, 2026.
Ryan designs and builds the cart and tests it on local orchards and vineyards. That keeps iteration fast and keeps the work tied to problems growers actually have.
Our approach is to understand why the established answer exists before replacing it, and to only count what the field data supports.
Free field demo
Tell us a little about your operation and we'll get back to you to set up an intro call.
See our privacy policy for how we handle your information.